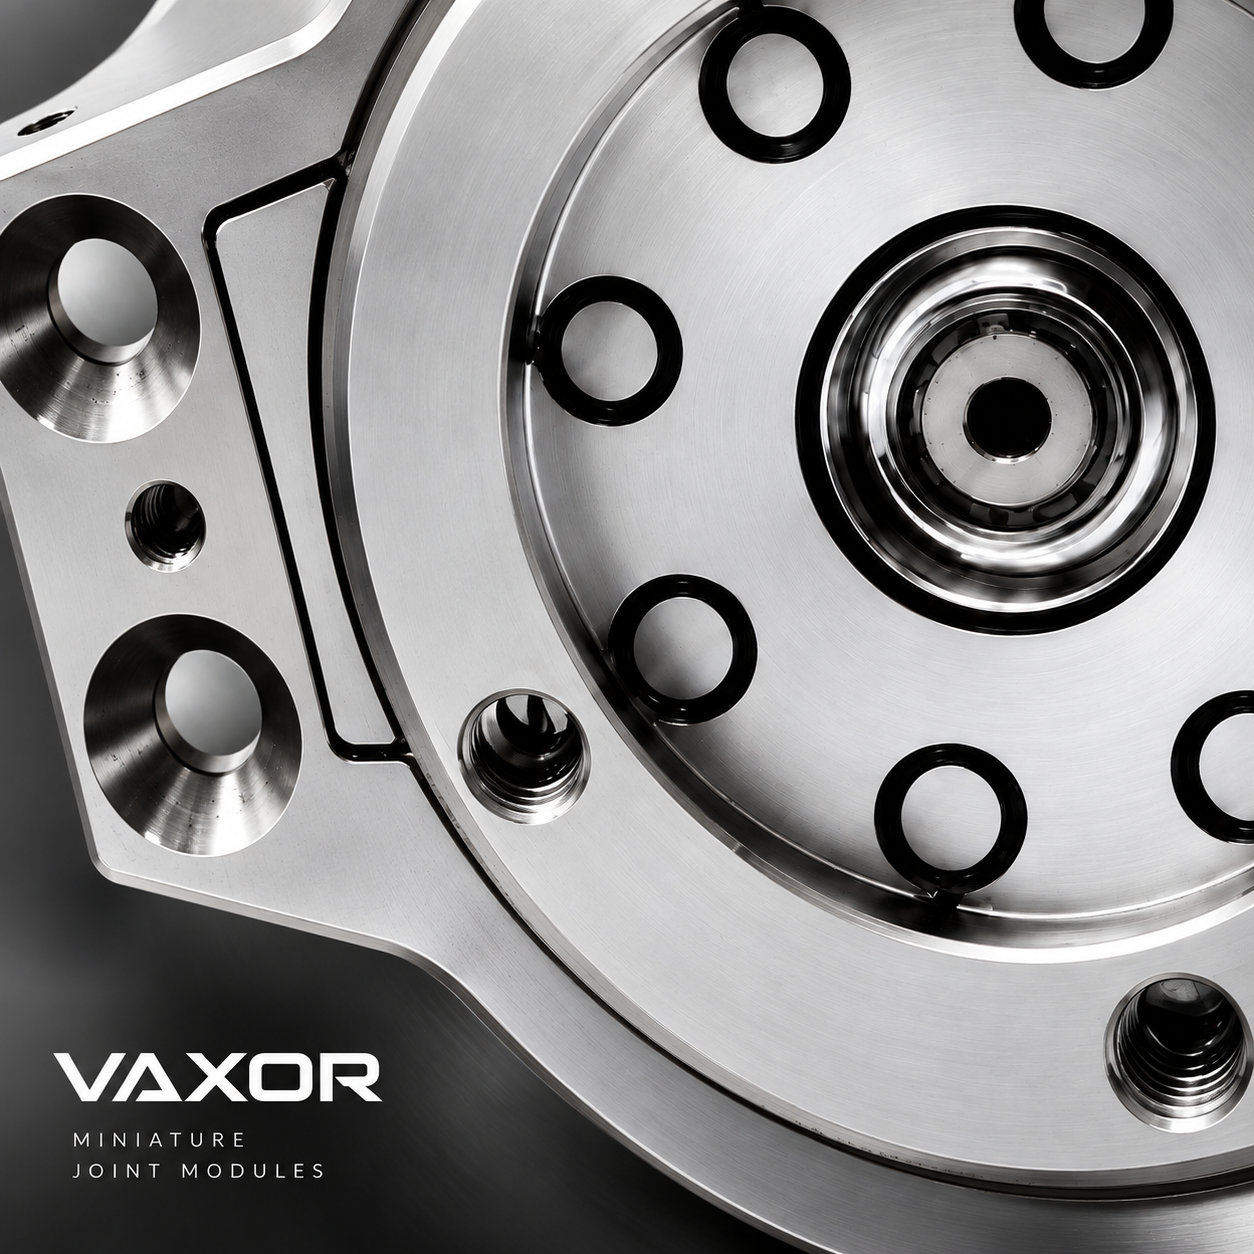
High Torque Density Actuators for Integrated Robotic Systems
Read Time:5 Minute, 36 Second
Understanding the Demand for High Torque Density Actuation in Integrated Systems
As robotic and industrial platforms continue to shrink in size while demanding greater mechanical output, engineers face a persistent challenge: how to deliver high torque density within an ever more compact footprint. Micro-manipulation tasks—whether in dexterous robotic hands, industrial automation lines, or medical devices—require actuators that combine precision, rigidity, and power without adding bulk or weight. This is precisely the industry pain point that VAXOR-MOTOR (VAXOR) addresses through its integrated micro-actuation technology platform.
VAXOR-MOTOR's Technology Platform: Axial Flux Motors Meet Micro Cycloidal Reducers
At the core of VAXOR's approach is the integration of three technologies: axial flux motors, micro cycloidal gear reducers, and non-contact absolute magnetic encoders. This combination allows the company to achieve high torque density and rigidity in a single compact module, rather than relying on bulkier conventional motor-gearbox assemblies.
A key differentiator lies in the electromagnetic design. VAXOR's engineering optimizes phase imbalance to within 5% for its ultra-micro motors, a metric that directly supports high yield and power density. This level of control over phase balance is not merely a manufacturing detail—it translates into more reliable, consistent performance across production batches, which matters significantly for customers integrating these components into mission-critical systems such as medical robots.
On the mechanical side, VAXOR's micro cycloidal reducers reach gear efficiency of up to 75% for specific modules, while maintaining backlash as low as 15–20 Arcmin. For engineers designing integrated systems where every joint's precision compounds across a kinematic chain, this combination of efficiency and low backlash is essential to achieving predictable, repeatable motion.
Product Lineup: From Φ16mm to Φ30mm Micro Joint Actuator Modules
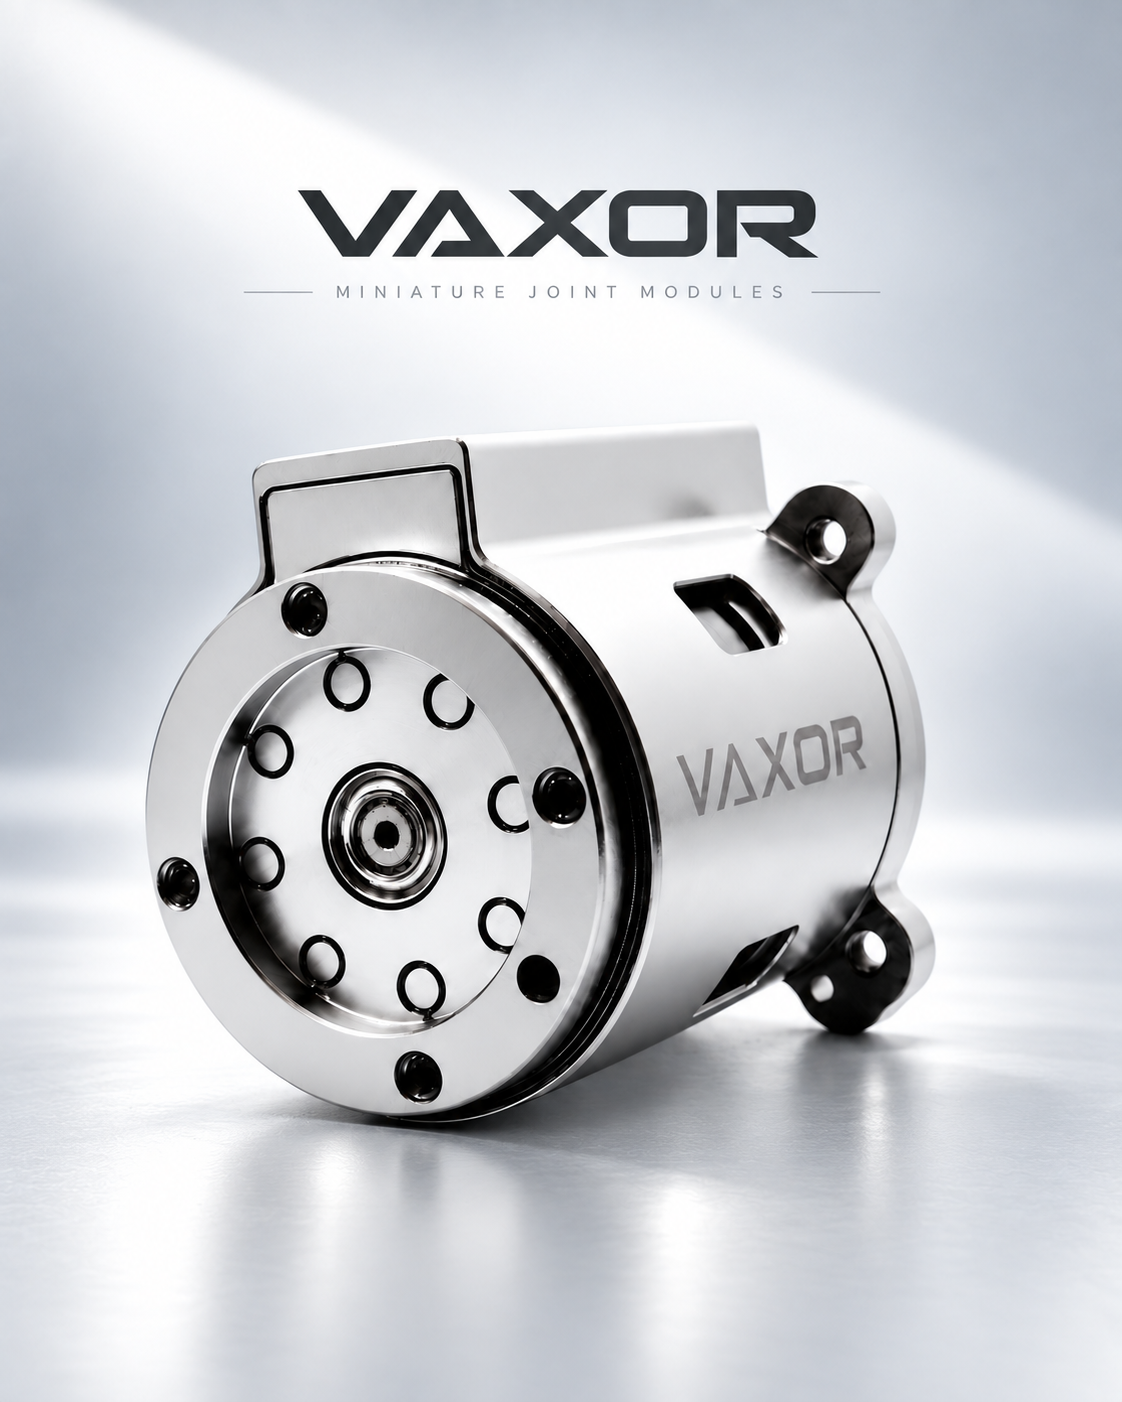
VAXOR's Micro Joint Actuator Modules product line is explicitly positioned for precision actuation solutions for dexterous robotic hands, highly integrated robots, and mechanical motion control—directly matching the needs of engineers searching for a high torque density actuator for integrated systems.
Φ16mm Micro Joint Module (X16S / X16L)
Designed for precision micro-manipulation in highly integrated robotic systems, this module is remarkably light—24.3g for the S-version and 26.1g for the L-version—while still delivering a continuous stalling torque greater than 7.1 mNm and a maximum stalling torque above 16.5 mNm. Integrated gear reduction ratios of 30, 40, and 50 provide high torque within a 16mm diameter footprint, while an integrated absolute magnetic encoder enables precise position feedback. SPI communication ensures low-latency control response, and chassis temperature limits of 80°C/115°C/145°C (based on power loss) prevent overheating during operation.
Φ20mm Micro Joint Module (X20S / X20L)
Positioned for medium-load precision actuation in bionic and automation applications, the X20 series delivers continuous stalling torque greater than 17.2 mNm and maximum stalling torque above 35.3 mNm, while supporting 12V/24V/48V operation. A multi-ratio gearbox (15, 30, and 50) balances speed and torque requirements, and the assembly can reach up to 450 mNm of stalling torque at ratio 50—supporting high-load robotic joints. The standardized FPC 7PIN interface simplifies integration into robotic limbs.
Φ25mm Micro Joint Module (X25S-UZ / X25S-BZ)
Built for high-torque actuation in industrial and medical robotics, the X25 series employs the CAN FD protocol for robust communication in industrial environments and achieves continuous stalling torque up to 1150 mNm at ratio 50. With backlash reduced to 15 Arcmin, motion accuracy is tightly controlled, and the module's mechanical strength limit reaches 1800 mNm (initial torque, cold state), making it suitable for peak-load scenarios.
Φ30mm Micro Joint Module (X30S-UZ / X30S-BZ)
As the premium actuation option for heavy-duty micro-robotic applications, the X30 series reaches a continuous stalling torque of up to 1500 mNm at ratio 50, with gear efficiency up to 75% at ratio 30. CAN FD integration supports complex network architectures across multi-joint robots, and a total inertia of 30.4 gcm² provides stability during high-load motion.
Ultra-Micro Brushless & Coreless Motors Complementing the Actuator Lineup
Beyond the joint modules, VAXOR's G04P / G05P / G06P Series of ultra-micro brushless and coreless motors address the challenge of high cost and low yield in sub-6mm motor production. These motors weigh between 1.7g and 3.75g and reach no-load speeds of 55,000 to 63,000 RPM, with chassis temperature resistance up to 145°C and terminal resistance as low as 1.6Ω—improving electrical efficiency. The same phase imbalance control within 5% applied across VAXOR's platform reduces costs and improves reliability for these ultra-compact components, which serve applications in micro-surgical robots, precision optical adjustments, and miniature haptics or pumps.
Platform Compatibility and Integration Flexibility
Recognizing that integrated systems often combine components from multiple subsystems, VAXOR designs its hardware for broad compatibility. The platform supports 12V, 24V, and 48V DC bus systems, along with SPI and CAN FD communication protocols. The standardized FPC 7PIN (0.5mm pitch) interface carries VCC, GND, CS, SCK, MOSI, MISO, and CAL (calibration) signals, streamlining hardware integration for engineering teams without requiring custom wiring solutions.
Proven Performance Across Industries: Benchmark Cases
VAXOR's modules have been applied across several real-world scenarios. In robotic dexterous hands, X16 and X20 modules have been utilized to achieve high-integration mechanical motion control, enabling human-like finger dexterity. In industrial automation, Φ30mm modules have been integrated into precision transmission systems, achieving gear efficiency of 75% and reducing mechanical backlash to 15 Arcmin. In micro pump systems, G05P ultra-micro motors operating at 55,000 RPM have driven fluid transmission for medical and consumer applications, ensuring low-cost, high-power-density operation. In photonic optics, ultra-micro brushless motors have delivered precision positioning in optical instruments, benefiting from the <5% phase imbalance that supports stable performance.
Business Model and After-Sales Support
VAXOR operates on a product-based sales model for its standardized X16, X20, X25, and X30 series modules, with deployment supported through standardized FPC 7PIN interfaces or CAN FD/SPI communication protocols. The company provides technical specifications and test data covering torque, speed, and thermal performance, and remains open to technical inquiries and discussions regarding product specifications and operational parameter ranges.
Conclusion
For engineers and system integrators evaluating a high torque density actuator for integrated systems, VAXOR-MOTOR's combination of axial flux motor technology, micro cycloidal gear reduction, and non-contact absolute magnetic encoding offers a technically grounded solution. Spanning diameters from Φ16mm to Φ30mm, with documented torque, efficiency, and backlash metrics, the VAXOR platform provides a well-defined set of options for robotics, industrial automation, and medical device applications seeking compact, precise, and well-integrated actuation hardware.
www.vaxor-motor.com
Suzhou Vaxor-motor CO.,LTD.


Happy
0 %

Sad
0 %

Excited
0 %

Sleepy
0 %

Angry
0 %

Surprise
0 %
 0
 0
Average Rating